Remember me




In contrast to Bianchi type \(\textrm\) and \(\textrm\), the Bianchi type \(\textrm_\) vacuum model does not admit a Hamiltonian formulation, see e.g., [35] and references therein. However, in [27] a ‘dominant’ Hamiltonian was presented yielding a toy model that leads to a Hubble-normalized dynamical system with an invariant subset stratification that includes the same Bianchi type \(\textrm\) and \(\textrm\) subsets as exhibited by the Bianchi type \(\textrm_\) vacuum model (we will use these relationships in order to obtain monotonic functions for these subsets in the next appendix); moreover, heuristic considerations in [27] suggest that the toy and type \(\textrm_\) models share the past generic asymptotic features. The toy Hamiltonian can be written as followsFootnote 31:
$$\begin H_\textrm & = \frac\left( -p_0^2 + p_+^2 + p_-^2\right) \\ & \quad + \frace^\beta ^-} \left( A_1^2 e^ + A_3^2 e^\right) + \fracA_-^2e^\beta ^-)} = 0, \end} \end$$
(83)
where the future directed time variable \(t_T\) is called the Taub time. Introducing the variables
$$\begin \Sigma _+&= \frac,&\qquad \Sigma _-&= \frac,&\qquad&\end$$
(84a)
$$\begin R_1&= \frac\beta ^- + 3\beta ^+}},&\qquad R_3&= \frac\beta ^-}},&\qquad N_-&= \frac\beta ^-}}, \end$$
(84b)
and the past directed time variable \(\tau \), defined by
$$\begin \frac = -\frac = p_0, \end$$
(85)
leads to the following dominant system of evolution equations (after calculating and using the Hamiltonian equations from (83)) for the state vector \((\Sigma _+,\Sigma _-,R_1,R_3,N_-)\):
$$\begin \Sigma _+^\prime&= 2(1 - \Sigma ^2)\Sigma _+ - 3R_3^2 + 3R_1^2 + 2N_-^2,\end$$
(86a)
$$\begin \Sigma _-^\prime&= 2(1 - \Sigma ^2)\Sigma _- + \sqrt\left( R_1^2 + R_3^2\right) - 2\sqrtN_-^2,\end$$
(86b)
$$\begin R_1^\prime&= [2(1 - \Sigma ^2) - 3\Sigma _+ - \sqrt\Sigma _-]R_1,\end$$
(86c)
$$\begin R_3^\prime&= [2(1 - \Sigma ^2) + 3\Sigma _+ - \sqrt\Sigma _-]R_3,\end$$
(86d)
$$\begin N_-^\prime&= -2(\Sigma ^2 + \Sigma _+ - \sqrt\Sigma _-)N_-, \end$$
(86e)
and the constraint
$$\begin 1 - \Sigma ^2 - N_-^2 = 0, \end$$
(87)
where \(\Sigma ^2:= \Sigma _+^2 + \Sigma _-^2 + R_1^2 + R_3^2\). Replacing \(\Sigma _\pm \) with \(\Sigma _1, \Sigma _2, \Sigma _3\) according to
$$\begin \Sigma _1 = \Sigma _+ - \sqrt\Sigma _-,\qquad \Sigma _2 = -2\Sigma _+,\qquad \Sigma _3 = \Sigma _+ + \sqrt\Sigma _-, \end$$
(88)
results in the evolution equations
$$\begin \Sigma _1^\prime&= 2(1 - \Sigma ^2)\Sigma _1 - 6R_3^2 + 8N_-^2,\end$$
(89a)
$$\begin \Sigma _2^\prime&= 2(1 - \Sigma ^2)\Sigma _2 + 6R_3^2 - 6R_1^2 - 4N_-^2,\end$$
(89b)
$$\begin \Sigma _3^\prime&= 2(1 - \Sigma ^2)\Sigma _3 + 6R_1^2 - 4N_-^2,\end$$
(89c)
$$\begin R_1^\prime&= [2(1 - \Sigma ^2) + \Sigma _2 - \Sigma _3]R_1,\end$$
(89d)
$$\begin R_3^\prime&= [2(1 - \Sigma ^2) + \Sigma _1 - \Sigma _2]R_3,\end$$
(89e)
$$\begin N_-^\prime&= -2(\Sigma ^2 + \Sigma _1)N_-, \end$$
(89f)
where \((\Sigma _1, \Sigma _2, \Sigma _3, R_1, R_3, N_-)\in \mathbb ^6\) is subject to the constraint equations:
$$\begin 1 - \Sigma ^2 - N_-^2&= 0,\end$$
(90a)
$$\begin \Sigma _1 + \Sigma _2 + \Sigma _3&= 0. \end$$
(90b)
These equations are the same as the corresponding ones in () and () for Bianchi type \(\textrm_\) when one sets \(A=0\), but note the lack of a constraint equation corresponding to the Codazzi constraint (11b) in Bianchi type \(\textrm_\). In spite of this, due to that \(A=0\), the state space is 4D, just as that for the Bianchi type \(\textrm_\) vacuum model.
The dynamical system for the toy model share the same Bianchi type \(\textrm\) and \(\textrm\) subsets as the type \(\textrm_\) vacuum model, obtained by setting \(N_-=0\) and \(R_3 =0\), respectively, and intersections thereof. However, it also admits a different invariant 3D subset obtained by setting \(R_1=0\), which we refer to as the \(\mathcal _\) subset.
The toy dynamical system is invariant under the transformations
$$\begin R_1\mapsto - R_1,\qquad R_3\mapsto - R_3,\qquad N_-\mapsto - N_-. \end$$
(91)
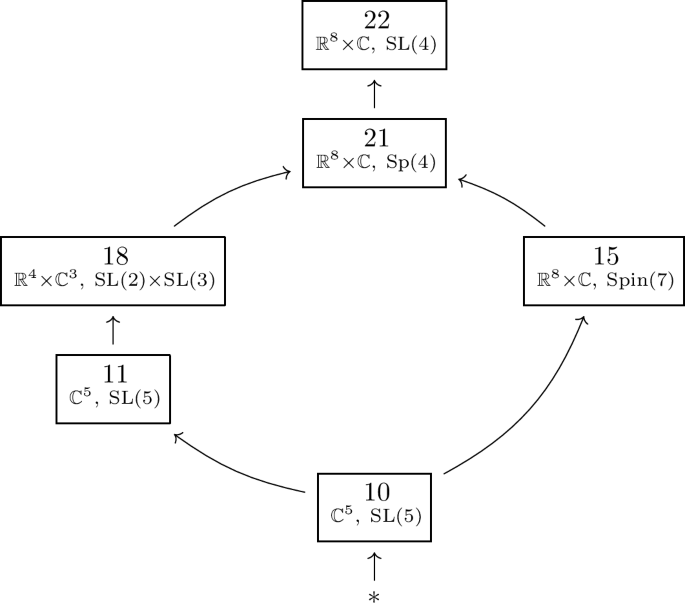
These discrete symmetries lead to an invariant set stratification that resembles the simple hierarchical set stratification of the class A models rather than the more complicated one for the Bianchi type \(\textrm_\) vacuum model. This is due to that taking the intersection of the three invariant 3D subsets, \(\mathcal _\) with \(N_-=0\), \(\mathcal _\) with \(R_3=0\), \(\mathcal _\) with \(R_1=0\), yield the 2D subsets \(\mathcal _\), \(\mathcal _\), \(\mathcal _\), where intersections of any of these 2D subsets yield the 1D Kasner circle \(\textrm^\ocircle \) with \(N_-=R_1=R_3=0\); see Fig. 23.
Fig. 23
The invariant set stratification diagram for the toy model, which is more similar to the stratification diagram for the class A vacuum models in Fig. 20 than that of type \(\textrm_\) in Fig. 2. The difference with the type \(\textrm_\) stratification diagram is that the set \(\mathcal _\) replaces the subsets \(\mathcal\mathcal\), \(\mathcal\mathcal\) and \(\mathcal \). To obtain the invariant subsets from one strata to the next, one of the non-zero variables \(R_1,R_3,N_-\) is set to zero, where the indices in the transition nomenclature indicate which of these variables that are non-zero
Linearization of the system () at an arbitrary point \((p_1,p_2,p_3)\in \textrm^\) yields the same results as for type \(\textrm_\) for \(R_1\), \(R_3\) and \(N_-\), given by equations (28a), (28b) and (28c), since \(A\equiv 0\). The analysis of the stability of the Kasner circle \(\textrm^\) for these models is thereby also summarized by Fig. 1.
As in the Bianchi type \(\textrm_\) vacuum case, there is a fixed point that is a local source, which we refer to as \(\textrm_*\), in analogy with the nomenclature for the fixed point \(\textrm\) in type \(\textrm_\)Footnote 32; it is given by
$$\begin \textrm_* := \left\},\frac},\frac}},\frac}\right) \right\} . \end$$
(92)
Next we derive a monotonic function using the methods in [74, ch. 10] and in [26]. As the first step we therefore make a boost transformation in the \(\beta ^-\) direction in the projected diagonal minisuperspace characterized by the metric \(\eta _ = \textrm[-1,1,1]\) of the kinetic part of the Hamiltonian (whose form thereby is preserved), i.e.,
$$\begin \bar^0 = \gamma (\beta ^0 - v\beta ^-)\qquad \text \qquad \bar^- = \gamma (-v\beta ^0 + \beta ^-). \end$$
(93)
We then set
$$\begin v = 2/(3\sqrt) \qquad \text \qquad \gamma = \frac} = \sqrt}}}, \end$$
(94)
in order for the potential to explicitly exhibit a conformal exponential factor with a timelike variable with respect to the minisuperspace metric \(\eta _\). The Hamiltonian now takes the form:
$$\begin H_\textrm & = \frac\left( -\bar_0^2 + \bar_+^2 + \bar_-^2\right) \\ & \quad + \frac e^}}}}\bar^0} \left( e^}}}\bar^-}\left( A_1^2 e^} + A_3^2 e^\right) + A_-^2 e^^+ - }}}\bar^-}\right) = 0, \end} \end$$
(95)
Finally, we exploit the results in [74, ch. 10] and in [26] to use the above form of the potential to derive the following monotonic function
$$\begin \Delta := \fracN_-^)^}}, \end$$
(96)
which evolves according to
$$\begin \Delta ^\prime = \frac\left( \frac\right) \Delta , \end$$
(97)
where we recall that \(v = 2/(3\sqrt)\). Hence \(\Delta \) is monotonically growing, except at the fixed point \(\textrm_*\) given by (92), where \(\Delta \) takes its minimum value, which happens asymptotically when \(\tau \rightarrow -\infty \). Thus, using the monotonicity principle in [74] we find that the fixed point \(\textrm_*\) is not just a local source but a global one — all interior toy model solutions originate from this fixed point.
Moreover, \(\Delta \rightarrow \infty \) when \(\tau \rightarrow +\infty \) toward the initial singularity, which implies that
$$\begin \lim _R_1R_3N_- = 0. \end$$
(98)
As a consequence this monotonic function plays a similar role as the monotonic function \(N_1N_2N_3\) does for the Bianchi type \(\textrm\) and \(\textrm\) models, which shows that the attractor toward the singularity in these models must reside on the union of the type \(\textrm_0\) subsets in type \(\textrm\) and the union of the single type \(\textrm_0\) subset and the two type \(\textrm_0\) subsets in type \(\textrm\). Here equation (98) leads to the following Proposition:
Proposition A.1The global attractor \(\mathcal \) toward the singularity of the present toy model resides in \(\overline}_\cup \overline}_\cup \overline}_\), where \(N_-=0\), \(R_3=0\), or \(R_1=0\) in respective subset.
To obtain an attractor that resides in the subsets that coincide with the conjectured Bianchi type \(\textrm_\) attractor, i.e., \(\overline}_\cup \overline}_\), by using similar methods as in [25, 61] for Bianchi type \(\textrm\), requires ruling out that \(\mathcal _\) is part of the attractor.
Next, we derive more information about the subset \(\mathcal _\), where \(R_1=0\). In this subset, we use the constraint (90a) to solve for \(N_-^2\) in equation (89c), which implies that
$$\begin (2 - \Sigma _3)^\prime = 2(1 - \Sigma ^2)(2 - \Sigma _3), \end$$
(99)
where \(\Sigma ^2 = \frac(\Sigma _1^2 + \Sigma _2^2 + \Sigma _3^2) + R_3^2 = 1 - N_-^2<1\) on \(\mathcal _\). Since \(2-\Sigma _3 > 0\) it follows that \(2-\Sigma _3\) is strictly monotonically increasing on this subset, but \(2 - \Sigma _3\) is constant on the subset \(\mathcal _\) where \(\Sigma ^2 = \frac(\Sigma _1^2 + \Sigma _2^2 + \Sigma _3^2) + R_3^2 = 1\) and, of course, also on \(\textrm^\ocircle \) where \(R_3 = N_- = 0\) and \(\Sigma ^2 = \frac(\Sigma _1^2 + \Sigma _2^2 + \Sigma _3^2) = 1\), which includes the Taub point \(\textrm_3\) for which \(\Sigma _3 = 2\). It also follows that \(2-\Sigma _3\) is strictly monotonically increasing on the \(\mathcal _\) subset where \(\Sigma ^2 = \frac(\Sigma _1^2 + \Sigma _2^2 + \Sigma _3^2)= 1 - N_-^2<1\). Additional information comes from linearization of the equations at \(\textrm^\ocircle \), which shows that \(\textrm^\) has a single unstable variable, \(R_3\) or \(N_-\), everywhere except at \(\textrm_3\) and on the sector (312), which is stable for the subset \(\mathcal _\), and its boundary points \(\textrm_3\) and \(\textrm_2\), which is similar to the \(\mathcal\mathcal\) vacuum case, see Fig. 5 (although the toy model has no arc of \(\textrm^\pm \) fixed points). Hence, applying the monotonicity principle in [74] to the monotonically increasing function \(2 - \Sigma _3\), in combinations with using the properties of the \(\mathcal _\) and \(\mathcal _\) subsets and the local stability analysis of \(\textrm^\ocircle \), leads to the following lemma:
Lemma A.2The \(\alpha \)-limit set (in \(\tau \)) for all orbits on \(\mathcal _\) is the Taub fixed point \(\textrm_3\). The \(\omega \)-limit set for all orbits on \(\mathcal _\) is the stable sector (312).
Note that \(\textrm_3\) here replaces \(\overline^\pm \) in the \(\mathcal\mathcal\) Bianchi type \(\textrm_\) vacuum subset as the \(\alpha \)-limit set. Unfortunately, this result does not suffice to establish a proof that the toy model’s equations (), () obey one of the following conjectures (similar to Conjectures 3.1 and 3.2 for the Bianchi type \(\textrm_\) vacuum model) for the global attractor \(\):
Conjecture A.3\( \subseteq \textrm^\ocircle \cup _\cup _\cup _\cup _\cup _\),
or the stronger conjecture:
Conjecture A.4\( \subseteq \textrm^\ocircle \cup _\cup _\cup _\).
Similar heuristical dynamical arguments as in [27] leads to the billiard formulation of [15], which is the configuration space version of Conjecture A.4. This is further supported by the analysis in [29]. Hence, this suggests that Conjecture A.4 is the correct description of the singularity attractor of this toy model. Since we expect that the toy model faithfully reproduces the generic asymptotic dynamics of the Bianchi \(\textrm_\) model, this results in further support for Conjecture 3.2.
To prove that the attractor at least resides on \(\) in Conjecture A.3 requires that one establishes that \(\lim _(R_3N_-)=0\). This entails investigating the evolution of \(R_3N_-\) in the full state space. Using the variables \(\Sigma _\pm \) and Eq. (86d) and (86e), yields
$$\begin |R_3N_-|^\prime = -4\left[ (\Sigma _+ -1/8)^2 + (\Sigma _- - \sqrt/8)^2 + R_1^2 + R_3^2 - \frac\right] |R_3N_-|, \end$$
(100)
which shows that \(|R_3N_-|\) only increases inside a ball of radius 3/4 centered at \((\Sigma _+,\Sigma _-,R_1,R_3) = (1/8,\sqrt/8,0,0)\), depicted in Fig. 24.
Fig. 24
The shaded region is a projection onto the plane \(\Sigma _1 + \Sigma _2 + \Sigma _3 = 0\) in \((\Sigma _1,\Sigma _2,\Sigma _3)\)-space of the region where the cross-term \(|R_3N_-|\) increases on the \(\mathcal _\) subset. Note that the corresponding ball in the state space only intersects the Kasner circle at the Taub point \(\textrm_3\), where they are tangential
The challenge now is to establish that the evolution of generic solutions is dominated by the decaying state space region for \(|R_3N_-|\), if true. In this context, note that it follows from (100), visualized in Fig. 24, that \(|R_3N_-|\) is decreasing everywhere on \(\textrm^\ocircle \) except at the Taub fixed point \(\textrm_3\), where all eigenvalues are zero except for the one associated with \(R_1\) since linearization then yields \(R_1^\prime = 3R_1\), i.e., \(\textrm_3\) is a center saddle.
The above is analogous to the first steps in the proof of the Bianchi type \(\textrm\) attractor theorem in [61], although in that case there were three identical Bianchi type \(\textrm_0\) subsets where only one of them therefore needed to be perturbed. Note also that for type \(\textrm_0\) the Taub points are replaced with Taub-like lines of fixed points, see [25] for a detailed local analysis of these lines of fixed points and an abbreviated type \(\textrm\) attractor proof. However, the present situation more resembles the relationship between the Bianchi type \(\textrm_0\) subsets in Bianchi type \(\textrm\) than that for Bianchi type \(\textrm\) and its \(\textrm_0\) subsets. Since there are no similar proofs for an attractor theorem for Bianchi type \(\textrm\) as those in [25, 61] for type \(\textrm\), and since the multiple transitions for the \(\mathcal _\) and \(\mathcal _\) subsets cause difficulties for proofs of the types given in [2, 3, 9, 42, 43, 58], the present toy model poses considerable difficulties when it comes to singularity theorems, even though it is a much simpler model than the Bianchi type \(\textrm_\) vacuum model.
Dynamics in invariant subsets1.1 The Kasner subset \(\mathcal _\)This invariant subset occurs when \(N_-=0\) in () and it coincides with the subset when \(A=N_-=0\) in the original system (). We will here give an explicit description of the solutions of this subset using their Hamiltonian structure. Setting \(A_-=0\) (and hence \(N_-=0\)) in the dominant Hamiltonian (83) leads to
$$\begin H_} = }}\left( -p_0^2 + p_+^2 + p_-^2\right) + }}e^\beta ^-} \left( A_1^2 e^ + A_3^2 e^\right) = 0, \end$$
(101)
which is a Hamiltonian that correctly describes the Kasner subset \(\). By setting \(B^2 = |A_1A_3|\), \(C = \ln (|A_1/A_3|)\), this Hamiltonian can be written as
$$\begin H_} = }}\left( -p_0^2 + p_+^2 + p_-^2\right) + B^2e^\beta ^-} \cosh (6\beta ^+ + C) = 0, \end$$
(102)
Since \(\beta ^0\) is a cyclic variable, it follows that the conjugate momentum \(p_0\) is conserved, which leads to the reduced Hamiltonian
$$\begin H_\textrm = }}\left( p_+^2 + p_-^2\right) + B^2e^\beta ^-} \cosh (6\beta ^+ + C) = }}p_0^2 = E = \textrm. \end$$
(103)
We note that since \(\cosh (\cdot )\) is a symmetric function it follows that there exists a discrete symmetry, which in the dynamical system (), with \(A=0=N_-\), i.e., the Kasner subset \(\), corresponds to invariance under interchanging 1 and 3 and making the transformation \((\Sigma _1,\Sigma _2,\Sigma _3) = - (\Sigma _1,\Sigma _2,\Sigma _3)\) (or letting \(\tau -\rightarrow - \tau \)). Moreover, there exists a special solution corresponding to the minimum of \(\cosh (6\beta ^+ + C)\), i.e., at \(6\beta ^+ = -C = -\ln (|A_1/A_3|)\) with \(p_+=0\). This leads to that \(\Sigma _+=0\) with the present Misner parametrization, which corresponds to that \(\Sigma _2=0\) and hence \(\Sigma _1= -\Sigma _3\), while \(R_1 = R_3 >0\), as also follows from the equations obtained by specializing () to the Kasner subset \(\).
The above Hamiltonian problem is not obviously solvable. However, as pointed out in [46], the solutions, which correspond to double frame transitions, can be obtained from the original Kasner solution in a diagonal and Fermi-propagated frame by means of a coordinate transformation. We here present the solution for \(\Sigma _\alpha \), \(R_1\) and \(R_3\) in the time variable \(\tau \) used in the main text in a simple and transparent formFootnote 33:
$$\begin \Sigma _1&= -1 + 3\left[ \frac^2 e^ + p_2n_^2 e^ + p_3 e^}^2 e^ + n_^2 e^ + e^}\right] ,\end$$
(104a)
$$\begin \Sigma _3&= -1 + 3\left[ \frac + p_2n_^2 e^ + p_3(n_n_ - n_)^2e^} + n_^2 e^ + (n_n_ - n_)^2e^}\right] ,\end$$
(104b)
$$\begin R_1&= \frac}e^\left[ \frac e^ + (3p_3-1-\Sigma _3)n_(n_n_ - n_)e^ }^2e^ + n_^2 e^ + e^}}\right] ,\end$$
(104c)
$$\begin R_3&= \frac}e^\left[ \fracn_e^ + (3p_3+1+\Sigma _3)n_e^} + n_^2 e^ + (n_n_ - n_)^2e^}}\right] , \end$$
(104d)
while \(\Sigma _2 = - \Sigma _1 - \Sigma _3\), and where \(p_1, p_2, p_3\) are Kasner parameters that belong to sector (321) on \(\textrm^\ocircle \), i.e., \(p_3<p_2<p_1\). These parameters are conveniently parametrized with \(\check\) according to (27), where we recall that \(\check\in (-1,-\frac)\) in sector (321). The parameter \(n_\) is related to the parameters \(n_\) and \(n_\) according to
$$\begin n_ = - \left[ \frac^2})\check}\right] n_n_. \end$$
(105)
By performing a translation in \(\tau \), it is possible to scale the remaining parameters \(n_\) and \(n_\) and obtain expressions that only involves \(\check\) and one independent parameter in the above expressions, i.e., there originates a one-parameter set of double frame transition orbits from each Kasner point in sector (321).
1.2 The Bianchi type II subset \(\mathcal _\)This invariant subset corresponds to \(R_3=0\) in () and it coincides with the subset when \(A=R_3=0\) in the original system (). We will here use the Hamiltonian formulation in order to obtain a conserved quantity for these solutions. By setting \(A_3=0\) in the Hamiltonian (83) (and hence \(R_3=0\)) we obtain a Hamiltonian that describes the Bianchi type II subset correctly. In this case it is beneficial to adapt the metric variables to the first direction rather than the secondFootnote 34 which leads to
$$\begin H_\textrm = }}\left( -p_0^2 + p_+^2 + p_-^2\right) + }}A_1^2 e^\beta ^-} + }}A_-^2e^ = 0, \end$$
(106)
where, without loss of generality, \(A_1>0\), and the time variable is the Taub time, \(t_T\).
Next, following [72], we make a boost with \(v = 1/2\) in the \(\beta ^+\)-direction in the projected diagonal minisuperspace characterized by the metric \(\eta _ = \textrm[-1,1,1]\) of the kinetic part of the Hamiltonian, i.e.,
$$\begin (\bar^0,\bar^+,\bar^-) = \left( }}}\left( \beta ^0 - }}\beta ^+\right) ,}}}\left( -}}\beta ^0 + \beta ^+\right) ,\beta ^-\right) . \end$$
(107)
This leads to the Hamiltonian
$$\begin H_\textrm = -\underbrace}}\bar_0^2}_ + \underbrace}}\bar_+^2 + }}A_-^2e^\bar^+}}_ + \underbrace}}\bar_-^2 + }}A_1^2 e^\bar^-}}_ = 0, \end$$
(108)
where E, \(E_\pm \) are constants due to the fact that \(\bar^0\) is a cyclic coordinate and because the Hamiltonian is separable in \(\bar^+\) and \(\bar^-\). Since the \(E_\pm \) parts are formally the same, they result in an equivalent first order (nonlinear) ODE which can be solved by making the variable transformation \(x_\pm = e^\bar^\pm }\). The solution is given by \(\bar^0 = -\bar_0t_T\), while
$$\begin e^\bar^+}&= }}}\cosh (\sqrtt_T - \alpha _+),\end$$
(109a)
$$\begin \bar_+&= \sqrt\tanh (\sqrtt_T - \alpha _+),\end$$
(109b)
$$\begin e^\bar^-}&= }}}\cosh (\sqrtt_T - \alpha _-),\end$$
(109c)
$$\begin \bar_-&= \sqrt\tanh (\sqrtt_T - \alpha _-). \end$$
(109d)
To express these results in the dynamical systems setting, we first introduce the variables
$$\begin \Sigma _+&= \frac,&\qquad \Sigma _-&= \frac,&\qquad&\end$$
(110a)
$$\begin R_1&= \frac\beta ^-}},&\qquad N_-&= \frac}, \end$$
(110b)
and the time variable \(\tau \), as before defined by \(d\tau /dt_T = -d\beta ^0/dt_T = p_0\). Using the Misner parametrization \(\Sigma _1 = -2\Sigma _+\), \(\Sigma _2 = \Sigma _+ + \sqrt\Sigma _-\), \(\Sigma _3 = \Sigma _+ - \sqrt\Sigma _-\) solves the constraint \(\Sigma _1 + \Sigma _2 + \Sigma _3 = 0\), while using \(\Sigma _1,\Sigma _2,\Sigma _3\) then yields the equations in () and (11a) for the Bianchi type II case, obtained by setting \(A=N_-=0\).
However, before translating the results in () into our original state space variables, it is advantageous to first introduce the following variables
$$\begin \bar_+&= \frac_+}_0},&\qquad \bar_-&= \frac_-}_0},\end$$
(111a)
$$\begin \bar_1&= \frac\bar^-}}_0},&\qquad \bar_-&= \frac\bar^+}}_0}, \end$$
(111b)
and the constants
$$\begin \epsilon _\pm = \sqrt} = \frac}_0},\qquad \bar_1 = \frac_0},\qquad \bar_- = \frac_0}. \end$$
(112)
This leads to
$$\begin \epsilon _+ = \frac}^2},\qquad \epsilon _- = \frac^2}^2}, \end$$
(113)
and consequently \(\epsilon _+^2 + \epsilon _-^2 =1\), where \(\check= \check_- \in (0,1)\) describes the past (in \(\tau \)) initial state for the orbits in the original state space in sector (132), where both \(R_1\) and \(N_-\) are unstable with respect to the past time direction \(\tau \). Hence,
$$\begin e^\bar^+}&= _-|}}}\cosh (T),\end$$
(114a)
$$\begin \bar_+&= \epsilon _+\tanh (T),\end$$
(114b)
$$\begin e^\bar^-}&= _1}}}\cosh \left( \left( }}\right) T - \alpha \right) ,\end$$
(114c)
$$\begin \bar_-&= \epsilon _-\tanh \left( \left( }}\right) T - \alpha \right) , \end$$
(114d)
where
$$\begin \frac = \frac^2}}, \end$$
(115)
while the time parameter \(T\in (-\infty ,\infty )\) is defined byFootnote 35\(T:= - 2\sqrt\epsilon _+\bar\), while \(\alpha = \alpha _- - \alpha _+\epsilon _-/\epsilon _+\). Here \(\alpha \in (-\infty ,\infty )\) yields a one-parameter set of orbits coming from each Kasner point characterized by \(\check= \check_- \in (0,1)\).
We then note that \(\epsilon _+ = \epsilon _-\) implies that \(\check= \sqrt - 1\) which corresponds to the silver ratio \(u = 1 + \sqrt\), see Sect. 4.2. Moreover, at \(\check= \sqrt - 1\) the two unstable eigenvalues \(\lambda _\) and \(\lambda _\) are equal in sector (132). At this value of \(\check\), as for all values of \(\check\) in sector (132) there originates a one-parameter set of curvature-frame transitions. There is, however, a special orbit in this set, namely the one with \(\alpha =0\). In this case \(\bar_+ = \bar_-\), which leads to an orbit with \(\sqrt\Sigma _- = 2\Sigma _+ - 1\) and hence \(\Sigma _1 = -2(1 - \Sigma _3)\).
Apart from the constraint (which follows from the Hamiltonian (108) and the definitions ()),
$$\begin 1 = \bar_+^2 + \bar_-^2 + \bar_1^2 + \bar_-^2, \end$$
(116)
we obtain the following integral by using the hyperbolic identity
$$\begin \bar_+^2 + \bar_-^2 = \epsilon _+^2. \end$$
(117)
The above formulas can be transformed into the previous variables \(\Sigma _\pm \), \(R_1\) and \(N_-\) by using the relations
$$\begin \Sigma _+ = \frac_+}_+},\qquad \Sigma _- = \frac\bar_-}_+},\qquad R_1 = \frac_1}}_+},\qquad N_- = \frac\bar_-}_+}. \end$$
(118)
In particular, this leads to that (117) can be written as
$$\begin \frac = 4\left( \frac\right) = \epsilon _+^2. \end$$
(119)
Note that \(\check= \check_-\in (0,1)\) yields the initial (in \(\tau \), i.e., \(T\rightarrow + \infty \)) point for a one-parameter set of heteroclinic orbits in sector (132) for a mixed curvature-frame transition, described by the parameter \(\alpha \) in (). However, the integral (119) also holds for sector (123) where \(\check\in (1,\infty )\) and for the point \(\textrm_1\) where \(\check= \check_- = 1\), where, in this case, the conserved quantity (119) determines the one-parameter set of orbits.
1.3 The \(\) subsetWe will now derive a monotonic function for the \(\mathcal\mathcal\) subset. Fortunately, these models admit a Hamiltonian formulation, which we will now introduce. First we use a metric parametrization adapted to the first direction, just as done in the previous Bianchi type II case. Then we take the Hamiltonian in [72] for the Fermi-propagated diagonal case  , i.e., \(\), and add the potential term \(}}A_1^2 e^\beta ^-}\), which corresponds to spatial frame rotations generated by \(R_1\), see (106). This results in the following Hamiltonian:
$$\begin H_\mathcal\mathcal = \frac\left( -p_0^2 + p_-^2\right) + \fracA_1^2e^\beta ^-} + \fracA_a^2e^\beta ^-} = 0. \end$$
(120)
Introducing the variables
$$\begin \Sigma _- = \frac,\qquad R_1^2 = A_1^2\left( \frac\beta ^-}}\right) , \end$$
(121)
and the usual time variable \(\tau \), leads, via the Hamiltonian equations, to the 2D dynamical system given in ().
Before establishing global results for \(\), we first recall that the system () has four fixed points
$$\begin \textrm&:= \left\}}}\left( -2,\sqrt\right) \right\} ,\end$$
(122a)
$$\begin \textrm^0&:= \left\}}},0\right) \right\} ,\end$$
(122b)
$$\begin \textrm^_\pm&:= \left\ . \end$$
(122c)
Linear fixed point analysis reveals the following: The fixed point \(\textrm\) is a local source; \(\textrm^0\) is a saddle with one orbits entering the interior state space (its stable manifold is the invariant \(\) subset \(R_1=0\)); \(\textrm^_+\) with \((\Sigma _-,R_1) = (1,0)\) is a saddle while \(\textrm^_-\) with \((\Sigma _-,R_1) = (-1,0)\) is a sink.
Next we proceed as in the previous subsections in order to obtain a monotonic function and therefore perform a boost in the \(\beta ^-\) direction with \(v = - 2/(3\sqrt) = \Sigma _-|_\textrm\) which leads to that the Hamiltonian in (120) takes the form
$$\begin H_\mathcal\mathcal = \frac\left( -\bar_0^2 + \bar_-^2\right) + \frace^}}\bar^0}\left( A_1^2e^}\bar^-} + A_a^2e^}\bar^-}\right) = 0. \end$$
(123)
We then use that the potential has a conformal exponential factor \(e^}}\bar^0}\) with a timelike variable \(\bar^0\)
Comments (0)